Clock sync from BROAD on: the LED cycle, the clock model kept on it, and BG's offset servo and skew fit. More...
#include </builds/monado/monado/src/xrt/tracking/constellation/t_led_sync_refinement.h>
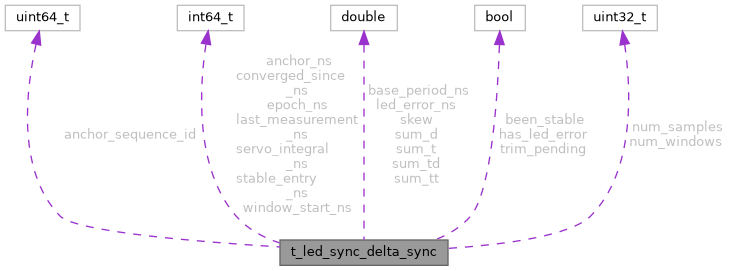
Data Fields | |
| uint64_t | anchor_sequence_id |
| The camera frame the clock model last matched the LED cycle at, its drift is measured from here. | |
| timepoint_ns | anchor_ns |
| timepoint_ns | epoch_ns |
| Host time the published offset is valid at, the skew extrapolates from here. | |
| double | skew |
| Estimated clock skew, device vs host, in ns per ns. | |
| time_duration_ns | servo_integral_ns |
| Sum of all servo corrections this BG session. | |
| double | led_error_ns |
| Smoothed offset of the LEDs from the exposure, as the servo correction that would center them. | |
| bool | has_led_error |
| double | base_period_ns |
| The frame period the LED cycle is trimmed from, set when BROAD starts and moved onto each trusted estimate. | |
| bool | trim_pending |
| The skew changed and the new cycle still has to be sent. | |
| timepoint_ns | last_measurement_ns |
| Host time of the last accepted measurement, for the no-data watchdog. | |
| uint32_t | num_windows |
| Skew windows fitted since BG was entered. | |
| timepoint_ns | converged_since_ns |
| When the fitted rate last started staying under the STABLE gate, 0 if it isn't. | |
| bool | been_stable |
| Whether this sync has reached STABLE, BG comes back from it warm. | |
| timepoint_ns | stable_entry_ns |
| Host time STABLE was entered. | |
| uint32_t | num_samples |
| Least-squares window of the phase deviation against time. | |
| timepoint_ns | window_start_ns |
| double | sum_t |
| double | sum_tt |
| double | sum_d |
| double | sum_td |
Detailed Description
Clock sync from BROAD on: the LED cycle, the clock model kept on it, and BG's offset servo and skew fit.
Field Documentation
◆ anchor_sequence_id
| uint64_t t_led_sync_delta_sync::anchor_sequence_id |
The camera frame the clock model last matched the LED cycle at, its drift is measured from here.
Referenced by delta_sync_reanchor().
◆ base_period_ns
| double t_led_sync_delta_sync::base_period_ns |
The frame period the LED cycle is trimmed from, set when BROAD starts and moved onto each trusted estimate.
Referenced by delta_sync_reanchor(), and delta_sync_rebase().
◆ been_stable
| bool t_led_sync_delta_sync::been_stable |
Whether this sync has reached STABLE, BG comes back from it warm.
Referenced by bg_update_skew().
◆ converged_since_ns
| timepoint_ns t_led_sync_delta_sync::converged_since_ns |
When the fitted rate last started staying under the STABLE gate, 0 if it isn't.
Referenced by bg_update_skew().
◆ epoch_ns
| timepoint_ns t_led_sync_delta_sync::epoch_ns |
Host time the published offset is valid at, the skew extrapolates from here.
Referenced by delta_sync_set_skew().
◆ last_measurement_ns
| timepoint_ns t_led_sync_delta_sync::last_measurement_ns |
Host time of the last accepted measurement, for the no-data watchdog.
◆ led_error_ns
| double t_led_sync_delta_sync::led_error_ns |
Smoothed offset of the LEDs from the exposure, as the servo correction that would center them.
Referenced by bg_send_correction(), bg_update_led_error(), and model_clock_offset_ns().
◆ num_samples
| uint32_t t_led_sync_delta_sync::num_samples |
Least-squares window of the phase deviation against time.
Referenced by bg_update_skew().
◆ num_windows
| uint32_t t_led_sync_delta_sync::num_windows |
Skew windows fitted since BG was entered.
Referenced by bg_update_skew().
◆ servo_integral_ns
| time_duration_ns t_led_sync_delta_sync::servo_integral_ns |
Sum of all servo corrections this BG session.
Referenced by bg_send_correction(), and bg_update_skew().
◆ skew
| double t_led_sync_delta_sync::skew |
Estimated clock skew, device vs host, in ns per ns.
Referenced by bg_update_skew(), delta_sync_rebase(), and delta_sync_set_skew().
◆ stable_entry_ns
| timepoint_ns t_led_sync_delta_sync::stable_entry_ns |
Host time STABLE was entered.
◆ trim_pending
| bool t_led_sync_delta_sync::trim_pending |
The skew changed and the new cycle still has to be sent.
Referenced by delta_sync_maintain_clock(), and delta_sync_set_skew().
The documentation for this struct was generated from the following file:
- tracking/constellation/t_led_sync_refinement.h
