Loading...
Searching...
No Matches
xrt::tracking::constellation::optimizer::ImuBias< T > Struct Template Reference
A full-state IMU bias, with Accelerometer Bias, Gyroscope Bias, and Accelerometer Scale. More...
#include </builds/monado/monado/src/xrt/tracking/constellation/optimizer/imu_preintegration.hpp>
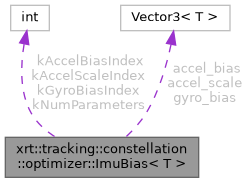
Collaboration diagram for xrt::tracking::constellation::optimizer::ImuBias< T >:
Public Member Functions | |
| ImuBias (const Vector3< T > &accel_bias, const Vector3< T > &gyro_bias, const Vector3< T > &accel_scale) | |
| ImuBias (Eigen::Ref< const Vector< T, kNumParameters > > parameters) | |
| void | pack (Eigen::Ref< Vector< T, kNumParameters > > parameters) |
| ImuBias< ImuBiasJet > | seed () const |
Data Fields | |
| Vector3< T > | accel_bias |
| Vector3< T > | gyro_bias |
| Vector3< T > | accel_scale |
Detailed Description
template<typename T>
struct xrt::tracking::constellation::optimizer::ImuBias< T >
struct xrt::tracking::constellation::optimizer::ImuBias< T >
A full-state IMU bias, with Accelerometer Bias, Gyroscope Bias, and Accelerometer Scale.
Everything here belongs to one physical IMU, so a solve over several devices holds one of these per device. The strength of gravity is shared by all of them and lives in WorldGravity instead.
The documentation for this struct was generated from the following file:
- tracking/constellation/optimizer/imu_preintegration.hpp
