Loading...
Searching...
No Matches
xrt::tracking::constellation::optimizer::PitchRoll< T > Struct Template Reference
A parameter block for a camera with 2 degrees of freedom, pitch and roll. Yaw is fixed to 0, and it has no position. More...
#include </builds/monado/monado/src/xrt/tracking/constellation/optimizer/internal_math.hpp>
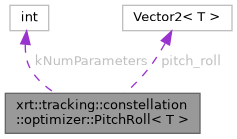
Collaboration diagram for xrt::tracking::constellation::optimizer::PitchRoll< T >:
Public Member Functions | |
| void | toQuaternion (Quaternion< T > &q) const |
| Eigen::Transform< T, 3, Eigen::Isometry > | toTransform () const |
| PitchRoll (Eigen::Ref< const Vector< T, kNumParameters > > parameters) | |
Data Fields | |
| Vector2< T > | pitch_roll |
Static Public Attributes | |
| static constexpr int | kNumParameters = 2 |
Detailed Description
template<typename T>
struct xrt::tracking::constellation::optimizer::PitchRoll< T >
struct xrt::tracking::constellation::optimizer::PitchRoll< T >
A parameter block for a camera with 2 degrees of freedom, pitch and roll. Yaw is fixed to 0, and it has no position.
The documentation for this struct was generated from the following file:
- tracking/constellation/optimizer/internal_math.hpp
