Frameserver that generates frames. More...
#include <xrt/xrt_frameserver.h>
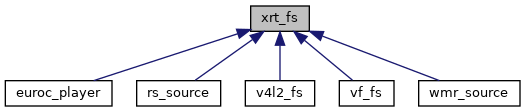
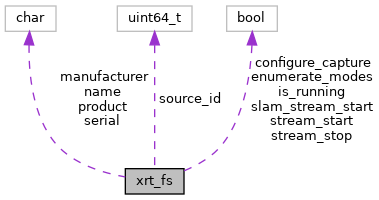
Static Public Member Functions | |
| static xrt_result_t | xrt_fs_enumerate_modes (struct xrt_fs *xfs, struct xrt_fs_mode **out_modes, uint32_t *out_count) |
| Enumerate all available modes that this frameserver supports. | |
| static xrt_result_t | xrt_fs_configure_capture (struct xrt_fs *xfs, struct xrt_fs_capture_parameters *cp) |
| Set the capture parameters, not all types of parameters may be supported on some capture devices. | |
| static xrt_result_t | xrt_fs_stream_start (struct xrt_fs *xfs, struct xrt_frame_sink *xs, enum xrt_fs_capture_type capture_type, uint32_t descriptor_index) |
| Start the capture stream. | |
| static xrt_result_t | xrt_fs_slam_stream_start (struct xrt_fs *xfs, struct xrt_slam_sinks *sinks) |
| Setup SLAM sinks for all the sensors a SLAM implementation may supports and start the frame server stream. | |
| static xrt_result_t | xrt_fs_stream_stop (struct xrt_fs *xfs) |
| Stop the capture stream. | |
| static xrt_result_t | xrt_fs_is_running (struct xrt_fs *xfs, bool *out_is_running) |
| Is the capture stream running. | |
Data Fields | |
| char | name [512] |
| Name of the frame server source, from the subsystem. | |
| char | product [32] |
| Frame server product identifier, matches the prober device. | |
| char | manufacturer [32] |
| Frame server manufacturer, matches the prober device. | |
| char | serial [32] |
| Frame server serial number, matches the prober device. | |
| uint64_t | source_id |
| All frames produced by this frameserver are tagged with this id. | |
| xrt_result_t(* | enumerate_modes )(struct xrt_fs *xfs, struct xrt_fs_mode **out_modes, uint32_t *out_count) |
| Enumerate all available modes that this frameserver supports. | |
| xrt_result_t(* | configure_capture )(struct xrt_fs *xfs, struct xrt_fs_capture_parameters *cp) |
| Set the capture parameters, not all types of parameters may be supported on some capture devices. | |
| xrt_result_t(* | stream_start )(struct xrt_fs *xfs, struct xrt_frame_sink *xs, enum xrt_fs_capture_type capture_type, uint32_t descriptor_index) |
| Start the capture stream. | |
| xrt_result_t(* | slam_stream_start )(struct xrt_fs *xfs, struct xrt_slam_sinks *sinks) |
| Setup SLAM sinks for all the sensors a SLAM implementation may supports and start the frame server stream. | |
| xrt_result_t(* | stream_stop )(struct xrt_fs *xfs) |
| Stop the capture stream. | |
| xrt_result_t(* | is_running )(struct xrt_fs *xfs, bool *out_is_running) |
| Is the capture stream running. | |
Detailed Description
Frameserver that generates frames.
Multiple subframes (like stereo and mipmaps) can be generate in one frame.
Member Function Documentation
◆ xrt_fs_configure_capture()
|
inlinestatic |
Set the capture parameters, not all types of parameters may be supported on some capture devices.
This function must not fail from a subset of requested parameters being unsupported!
Helper for calling through the function pointer.
References configure_capture.
◆ xrt_fs_enumerate_modes()
|
inlinestatic |
Enumerate all available modes that this frameserver supports.
This may return no modes, which should be checked by the caller. In this case, the frameserver does not support streaming frames.
Helper for calling through the function pointer.
References enumerate_modes.
◆ xrt_fs_is_running()
|
inlinestatic |
Is the capture stream running.
Helper for calling through the function pointer.
References is_running.
◆ xrt_fs_slam_stream_start()
|
inlinestatic |
Setup SLAM sinks for all the sensors a SLAM implementation may supports and start the frame server stream.
Use xrt_fs::stream_start instead if you only need the image stream.
- Note
- Having this method extends the scope of the frameserver to something more akin to a generic data source instead of just serving frames.
- Todo:
- Fix this incongruence. Maybe rename the interface to xrt_data_source.
Helper for calling through the function pointer.
References slam_stream_start.
◆ xrt_fs_stream_start()
|
inlinestatic |
Start the capture stream.
- Parameters
-
xfs The frameserver xs The sink for this frameserver to push frames into capture_type The type of capture this is descriptor_index The mode the stream should start with.
Helper for calling through the function pointer.
References stream_start.
◆ xrt_fs_stream_stop()
|
inlinestatic |
Field Documentation
◆ configure_capture
| xrt_result_t(* xrt_fs::configure_capture) (struct xrt_fs *xfs, struct xrt_fs_capture_parameters *cp) |
Set the capture parameters, not all types of parameters may be supported on some capture devices.
This function must not fail from a subset of requested parameters being unsupported!
Referenced by euroc_player_create(), rs_source_create(), u_frameserver_populate_function_pointers(), v4l2_fs_create(), wmr_source_create(), and xrt_fs_configure_capture().
◆ enumerate_modes
| xrt_result_t(* xrt_fs::enumerate_modes) (struct xrt_fs *xfs, struct xrt_fs_mode **out_modes, uint32_t *out_count) |
Enumerate all available modes that this frameserver supports.
This may return no modes, which should be checked by the caller. In this case, the frameserver does not support streaming frames.
Referenced by euroc_player_create(), rs_source_create(), u_frameserver_populate_function_pointers(), v4l2_fs_create(), wmr_source_create(), and xrt_fs_enumerate_modes().
◆ is_running
| xrt_result_t(* xrt_fs::is_running) (struct xrt_fs *xfs, bool *out_is_running) |
Is the capture stream running.
Referenced by euroc_player_create(), rs_source_create(), u_frameserver_populate_function_pointers(), v4l2_fs_create(), wmr_source_create(), and xrt_fs_is_running().
◆ manufacturer
| char xrt_fs::manufacturer[32] |
Frame server manufacturer, matches the prober device.
Referenced by euroc_player_create(), rs_source_create(), v4l2_fs_create(), and wmr_source_create().
◆ name
| char xrt_fs::name[512] |
Name of the frame server source, from the subsystem.
Referenced by ipcproto.common.Arg::__init__(), ipcproto.common.Call::__init__(), bindings.Profile::__init__(), ipcproto.common.Arg::dump(), ipcproto.common.Call::dump(), euroc_player_create(), ipcproto.common.Arg::get_func_argument_in(), ipcproto.common.Arg::get_func_argument_out(), ipcproto.common.Arg::get_struct_field(), gui_program::gui_scene_calibrate(), rs_source_create(), v4l2_fs_create(), wmr_source_create(), ipcproto.common.Call::write_call_decl(), ipcproto.common.Call::write_handler_decl(), ipcproto.common.Call::write_receive_decl(), and ipcproto.common.Call::write_send_decl().
◆ product
| char xrt_fs::product[32] |
Frame server product identifier, matches the prober device.
Referenced by euroc_player_create(), rs_source_create(), v4l2_fs_create(), and wmr_source_create().
◆ serial
| char xrt_fs::serial[32] |
Frame server serial number, matches the prober device.
Referenced by euroc_player_create(), rs_source_create(), v4l2_fs_create(), and wmr_source_create().
◆ slam_stream_start
| xrt_result_t(* xrt_fs::slam_stream_start) (struct xrt_fs *xfs, struct xrt_slam_sinks *sinks) |
Setup SLAM sinks for all the sensors a SLAM implementation may supports and start the frame server stream.
Use xrt_fs::stream_start instead if you only need the image stream.
- Note
- Having this method extends the scope of the frameserver to something more akin to a generic data source instead of just serving frames.
- Todo:
- Fix this incongruence. Maybe rename the interface to xrt_data_source.
Referenced by euroc_player_create(), rs_source_create(), u_frameserver_populate_function_pointers(), wmr_source_create(), and xrt_fs_slam_stream_start().
◆ source_id
| uint64_t xrt_fs::source_id |
All frames produced by this frameserver are tagged with this id.
Referenced by euroc_player_create(), euroc_player_load_next_frame(), p_factory_ensure_slam_frameserver(), rs2xrt_frame(), rs_source_create(), v4l2_fs_mainloop(), vf_fs_frame(), and wmr_source_create().
◆ stream_start
| xrt_result_t(* xrt_fs::stream_start) (struct xrt_fs *xfs, struct xrt_frame_sink *xs, enum xrt_fs_capture_type capture_type, uint32_t descriptor_index) |
Start the capture stream.
- Parameters
-
xfs The frameserver xs The sink for this frameserver to push frames into capture_type The type of capture this is descriptor_index The mode the stream should start with.
Referenced by euroc_player_create(), rs_source_create(), u_frameserver_populate_function_pointers(), v4l2_fs_create(), wmr_source_create(), and xrt_fs_stream_start().
◆ stream_stop
| xrt_result_t(* xrt_fs::stream_stop) (struct xrt_fs *xfs) |
Stop the capture stream.
Referenced by euroc_player_create(), rs_source_create(), u_frameserver_populate_function_pointers(), v4l2_fs_create(), wmr_source_create(), and xrt_fs_stream_stop().
The documentation for this interface was generated from the following file:
