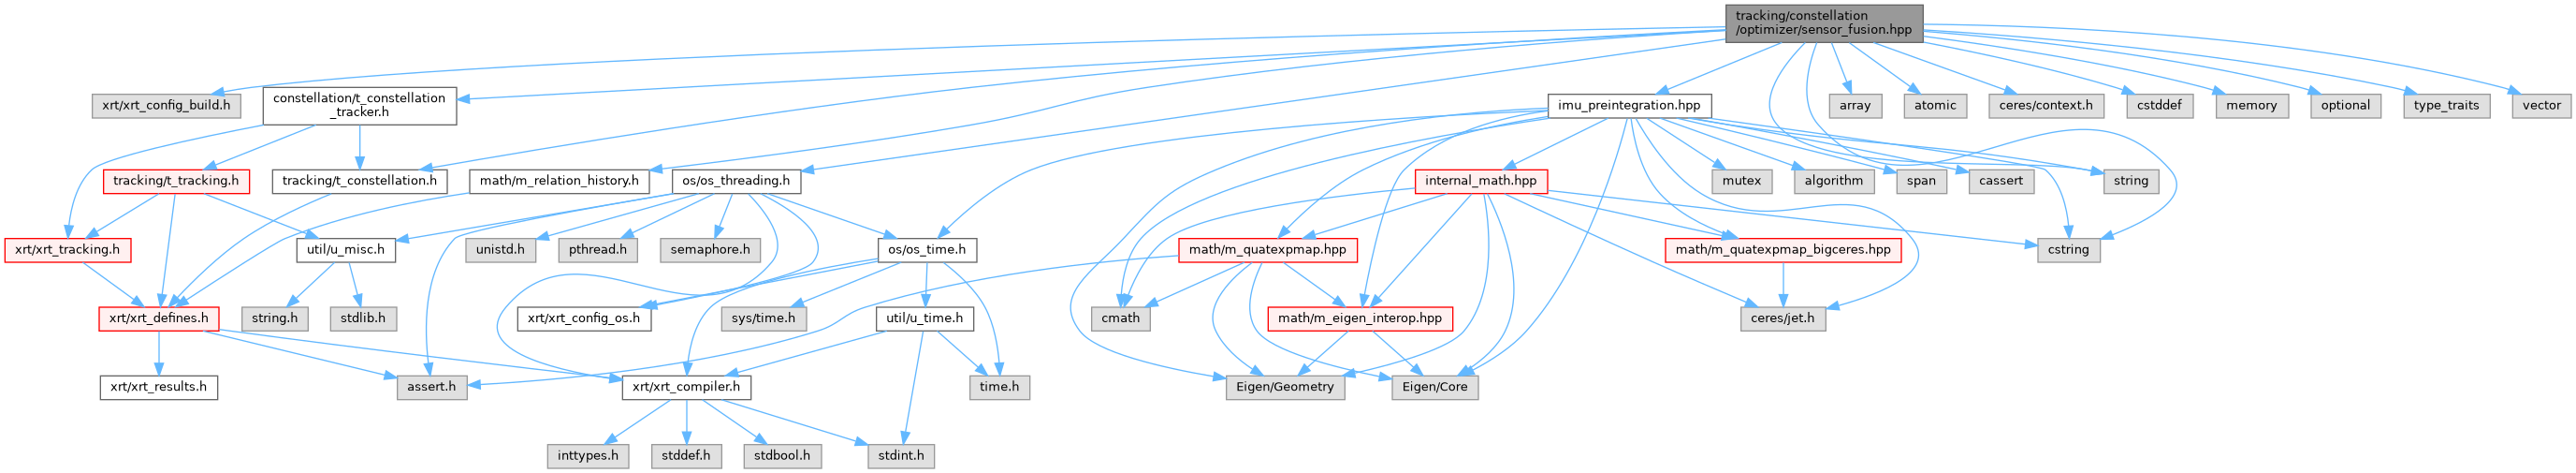
Constellation tracker sensor fusion.
More...
#include "xrt/xrt_config_build.h"
#include "os/os_threading.h"
#include "tracking/t_constellation.h"
#include "constellation/t_constellation_tracker.h"
#include "math/m_relation_history.h"
#include "imu_preintegration.hpp"
#include <array>
#include <atomic>
#include <ceres/context.h>
#include <cstddef>
#include <cstring>
#include <memory>
#include <optional>
#include <string>
#include <type_traits>
#include <vector>
Go to the source code of this file.
Constellation tracker sensor fusion.
- Author
- Beyley Cardellio ep1cm.nosp@m.1n10.nosp@m.n123@.nosp@m.gmai.nosp@m.l.com
◆ DevicePreintegrationState
| Enumerator |
|---|
| Dirty | Needs to be recomputed.
|
| Empty | Does not refer to any real pre-integration. This term contributes nothing and can be skipped.
|
| Integrated | This preintegration is complete and will never change.
|
◆ kImuBufferSize
| constexpr uint32_t xrt::tracking::constellation::optimizer::sensor_fusion::kImuBufferSize = 5000 |
|
staticconstexpr |
The number of IMU samples to keep in our ring buffer.
◆ kKeyframeSealLagKeyframes
| constexpr uint32_t xrt::tracking::constellation::optimizer::sensor_fusion::kKeyframeSealLagKeyframes = 2 |
|
staticconstexpr |
How many newer keyframes have to pile up before a keyframe gets sealed and marginalized.
◆ kMaxImuSamplesPerKeyframe
| constexpr uint32_t xrt::tracking::constellation::optimizer::sensor_fusion::kMaxImuSamplesPerKeyframe = 512 |
|
staticconstexpr |
The most IMU samples we ever expect to find between two keyframes.
At a 1KHz IMU and a keyframe every few tens of milliseconds the real count is well under a hundred, so this is generous headroom rather than a tight bound. Sizing the staging buffer off this instead of kImuBufferSize keeps it small enough to sit on the stack.
◆ kMaxQueuedCameraSamples
| constexpr uint32_t xrt::tracking::constellation::optimizer::sensor_fusion::kMaxQueuedCameraSamples = 32 |
|
staticconstexpr |
How many camera samples may be queued for the fusion thread before new ones start being dropped.
The fusion thread drains the whole queue every pass, so if this grows past even a handful, the thread has stalled a lot and we should just warn and start dropping them to not use an ever-increasing amount of RAM.
◆ kSlidingWindowSize
| constexpr uint32_t xrt::tracking::constellation::optimizer::sensor_fusion::kSlidingWindowSize = 3 |
|
staticconstexpr |
How many keyframes to keep in our sliding window.