Loading...
Searching...
No Matches
t_constellation_tracker_sample Struct Reference
Collaboration diagram for t_constellation_tracker_sample:
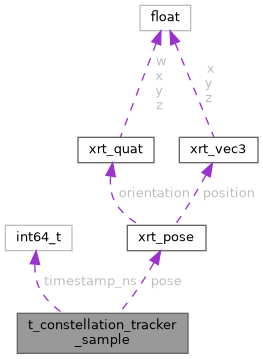
Data Fields | |
| int64_t | timestamp_ns |
| The time the original blobservation was made. | |
| uint64_t | sequence_id |
| The sequence ID of the mosaic. | |
| bool | has_world_pose |
Whether the world_pose field is valid or not. | |
| struct xrt_pose | world_pose |
| The pose of the device at the time of the blobservation. | |
| size_t | mosaic_index |
| The mosaic index of the camera that made the blobservation in question. | |
| size_t | camera_index |
| The index of the camera in the mosaic that made the blobservation in question. | |
| float | average_brightness |
| Average brightness of the detected blobs, from 0 (black) to 1 (pure white). | |
| struct t_constellation_tracker_sample_metrics | metrics |
| Metrics about the sample, such as reprojection error and matched LED count. | |
Field Documentation
◆ average_brightness
| float t_constellation_tracker_sample::average_brightness |
Average brightness of the detected blobs, from 0 (black) to 1 (pure white).
◆ camera_index
| size_t t_constellation_tracker_sample::camera_index |
The index of the camera in the mosaic that made the blobservation in question.
◆ has_world_pose
| bool t_constellation_tracker_sample::has_world_pose |
Whether the world_pose field is valid or not.
In certain cases, cameras are able to observe a device without themselves knowing where they are yet.
◆ metrics
| struct t_constellation_tracker_sample_metrics t_constellation_tracker_sample::metrics |
Metrics about the sample, such as reprojection error and matched LED count.
◆ mosaic_index
| size_t t_constellation_tracker_sample::mosaic_index |
The mosaic index of the camera that made the blobservation in question.
◆ sequence_id
| uint64_t t_constellation_tracker_sample::sequence_id |
The sequence ID of the mosaic.
◆ timestamp_ns
| int64_t t_constellation_tracker_sample::timestamp_ns |
The time the original blobservation was made.
◆ world_pose
| struct xrt_pose t_constellation_tracker_sample::world_pose |
The pose of the device at the time of the blobservation.
The documentation for this struct was generated from the following file:
- tracking/t_constellation.h
