PnP pose optimization using ceres. More...
#include "util/u_logging.h"#include "tracking/t_camera_models.hpp"#include "tracking/t_constellation.h"#include "math/m_api.h"#include "math/m_eigen_interop.hpp"#include "math/m_quatexpmap.hpp"#include "math/m_quatexpmap_bigceres.hpp"#include "constellation/camera_model.h"#include <Eigen/Core>#include <Eigen/Geometry>#include <Eigen/Eigenvalues>#include "ceres/autodiff_cost_function.h"#include "ceres/problem.h"#include "ceres/solver.h"#include "pose_optimize.hpp"#include "ransac.hpp"#include "math.hpp"#include <iostream>#include <stdio.h>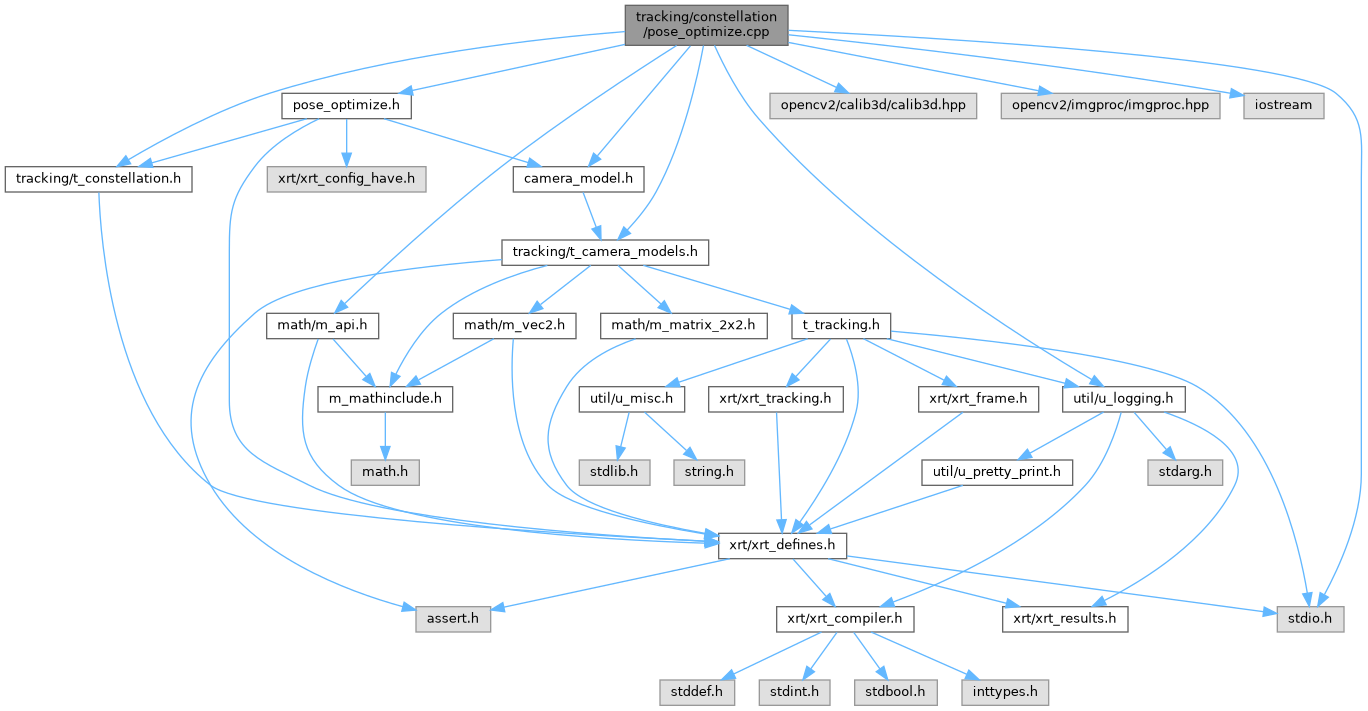
Macros | |
| #define | BAD_COVARIANCE_MATRIX (PoseStateCovarianceMatrix::Identity() * 1e6) |
| #define | BAD_WHITENING_MATRIX (PoseStateCovarianceMatrix::Identity() * 1e-3) |
Functions | |
| bool | xrt::tracking::constellation::optimizer::optimizePose (u_logging_level log_level, bool deterministic, const t_camera_model_params ¶ms, xrt_pose init_pose, t_blob *blobs, uint32_t num_blobs, t_constellation_tracker_led_model *leds_model, t_constellation_device_id_t device_id, xrt_pose &out_pose, RawPoseCovarianceMatrix out_covariance, RawPoseCovarianceMatrix out_whitening) |
| Does a pose optimization and RANSAC refinement on the given blobs and LED model, returning the optimized pose and covariance. | |
| void | xrt::tracking::constellation::optimizer::computePoseCovariance (u_logging_level log_level, const t_camera_model_params ¶ms, xrt_pose init_pose, t_blob *blobs, uint32_t num_blobs, t_constellation_tracker_led_model *leds_model, t_constellation_device_id_t device_id, RawPoseCovarianceMatrix out_covariance, RawPoseCovarianceMatrix out_whitening) |
| Computes the covariance of a pose given the initial pose, blobs, and LED model. | |
| void | xrt::tracking::constellation::optimizer::covariancePositionRadius (const RawPoseCovarianceMatrix &raw_covariance, xrt_vec3 &radii, xrt_quat &Q_cam_cov) |
| Computes the radii and covariance orientation from the 3x3 position part of the pose covariance matrix (3x eigenvalue, so 99%-ish probability containment). | |
Detailed Description
PnP pose optimization using ceres.
Function Documentation
◆ computePoseCovariance()
| void xrt::tracking::constellation::optimizer::computePoseCovariance | ( | u_logging_level | log_level, |
| const t_camera_model_params & | params, | ||
| xrt_pose | init_pose, | ||
| t_blob * | blobs, | ||
| uint32_t | num_blobs, | ||
| t_constellation_tracker_led_model * | leds_model, | ||
| t_constellation_device_id_t | device_id, | ||
| RawPoseCovarianceMatrix | out_covariance, | ||
| RawPoseCovarianceMatrix | out_whitening | ||
| ) |
Computes the covariance of a pose given the initial pose, blobs, and LED model.
- Parameters
-
log_level The logging level to use for debug output. params The camera model parameters. init_pose The initial pose estimate to start the optimization from. blobs The array of blobs to use for the optimization. num_blobs The number of blobs in the array. leds_model The LED model to use for the optimization. device_id The device ID to compute the covariance for. [out] out_covariance The covariance of the final pose will be written to this variable. [out] out_whitening The whitening matrix of the pose, must be non-nullptr if out_covariance is set.
- Returns
- void
References xrt::tracking::constellation::optimizer::computePoseCovariance().
Referenced by xrt::tracking::constellation::optimizer::computePoseCovariance().
◆ covariancePositionRadius()
| void xrt::tracking::constellation::optimizer::covariancePositionRadius | ( | const RawPoseCovarianceMatrix & | raw_covariance, |
| xrt_vec3 & | radii, | ||
| xrt_quat & | Q_cam_cov | ||
| ) |
Computes the radii and covariance orientation from the 3x3 position part of the pose covariance matrix (3x eigenvalue, so 99%-ish probability containment).
- Parameters
-
raw_covariance The raw pose covariance matrix to compute the radii and orientation from. [out] radii The radii of the position covariance will be written to this variable. [out] Q_cam_cov The orientation of the covariance will be written to this variable.
References xrt::tracking::constellation::optimizer::covariancePositionRadius(), xrt::auxiliary::math::map_quat(), xrt::auxiliary::math::map_vec3(), and U_LOG_E.
Referenced by xrt::tracking::constellation::optimizer::covariancePositionRadius().
◆ optimizePose()
| bool xrt::tracking::constellation::optimizer::optimizePose | ( | u_logging_level | log_level, |
| bool | deterministic, | ||
| const t_camera_model_params & | params, | ||
| xrt_pose | init_pose, | ||
| t_blob * | blobs, | ||
| uint32_t | num_blobs, | ||
| t_constellation_tracker_led_model * | leds_model, | ||
| t_constellation_device_id_t | device_id, | ||
| xrt_pose & | out_pose, | ||
| RawPoseCovarianceMatrix | out_covariance, | ||
| RawPoseCovarianceMatrix | out_whitening | ||
| ) |
Does a pose optimization and RANSAC refinement on the given blobs and LED model, returning the optimized pose and covariance.
- Parameters
-
log_level The logging level to use for debug output. params The camera model parameters. init_pose The initial pose estimate to start the optimization from. blobs The array of blobs to use for the optimization, will write to here to unmark outliers. num_blobs The number of blobs in the array. leds_model The LED model to use for the optimization. device_id The device ID to optimize the pose for. [out] out_pose The optimized pose will be written to this variable. [out] out_covariance The covariance of the final pose will be written to this variable, if not nullptr. [out] out_whitening The whitening matrix of the pose, must be non-nullptr if out_covariance is set.
- Returns
- true if the optimization was successful, false otherwise.
References xrt::tracking::constellation::optimizer::optimizePose(), xrt::tracking::constellation::optimizer::ransacPose(), U_LOG_IFL_D, and U_LOG_IFL_E.
Referenced by xrt::tracking::constellation::optimizer::optimizePose().
