Loading...
Searching...
No Matches
xrt::tracking::constellation::optimizer::PoseWithVelocity< T > Struct Template Reference
Pose with 9 degrees of freedom, translation, rotation, and linear velocity. More...
#include </builds/monado/monado/src/xrt/tracking/constellation/optimizer/internal_math.hpp>
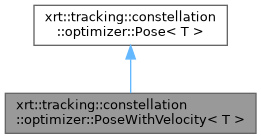
Inheritance diagram for xrt::tracking::constellation::optimizer::PoseWithVelocity< T >:
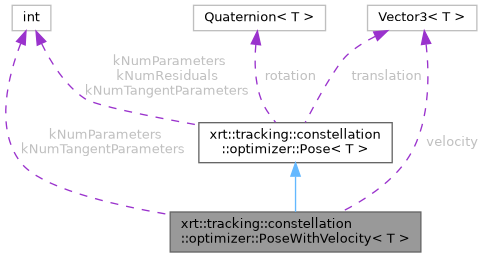
Collaboration diagram for xrt::tracking::constellation::optimizer::PoseWithVelocity< T >:
Public Member Functions | |
| PoseWithVelocity (xrt_pose p) | |
| template<typename Derived > | |
| PoseWithVelocity (xrt_pose p, const Vector3< Derived > &velocity) | |
| PoseWithVelocity (Eigen::Ref< const Vector< T, kNumParameters > > parameters) | |
| void | pack (Eigen::Ref< Vector< T, kNumParameters > > parameters) const |
 Public Member Functions inherited from xrt::tracking::constellation::optimizer::Pose< T > | |
| Pose (Quaternion< T > quat) | |
| Pose (xrt_pose pose) | |
| Pose (Eigen::Ref< const Vector< T, kNumParameters > > parameters) | |
| template<typename TransformType > | |
| Pose (const Eigen::Transform< TransformType, 3, Eigen::Isometry > &transform) | |
| void | pack (Eigen::Ref< Vector< T, kNumParameters > > parameters) const |
| Eigen::Transform< T, 3, Eigen::Isometry > | toTransform () const |
| void | getQuaternion (Quaternion< T > &q) const |
| xrt_pose | toXrtPose () const |
Data Fields | |
| Vector3< T > | velocity |
| Data Fields inherited from xrt::tracking::constellation::optimizer::Pose< T > | |
| Vector3< T > | translation |
| Quaternion< T > | rotation |
Static Public Attributes | |
| static constexpr int | kNumParameters = Pose<T>::kNumParameters + 3 |
| static constexpr int | kNumTangentParameters = Pose<T>::kNumTangentParameters + 3 |
| Static Public Attributes inherited from xrt::tracking::constellation::optimizer::Pose< T > | |
| static constexpr int | kNumParameters = 7 |
| Size of the parameter block handed to Ceres: (tX, tY, tZ), (qX, qY, qZ, qW). | |
| static constexpr int | kNumTangentParameters = 6 |
| Degrees of freedom the manifold exposes to the solver. | |
| static constexpr int | kNumResiduals = 6 |
Detailed Description
template<typename T>
struct xrt::tracking::constellation::optimizer::PoseWithVelocity< T >
struct xrt::tracking::constellation::optimizer::PoseWithVelocity< T >
Pose with 9 degrees of freedom, translation, rotation, and linear velocity.
Stored as a Pose with an extra 3-parameter vector for the velocity.
See PoseWithVelocityManifold for the correct way to optimize on this, which takes tangent space from 10 -> 9 parameters (quat exponential map).
The documentation for this struct was generated from the following file:
- tracking/constellation/optimizer/internal_math.hpp
