Shared internal helpers for every constellation rerun recorder. More...
#include "xrt/xrt_defines.h"#include "xrt/xrt_frame.h"#include "math/m_api.h"#include "math/m_vec3.h"#include "tracking/t_tracking.h"#include "tracking/t_constellation.h"#include "tracking/t_camera_models.hpp"#include <rerun.hpp>#include <algorithm>#include <array>#include <cassert>#include <cmath>#include <cstdint>#include <cstring>#include <format>#include <memory>#include <string>#include <vector>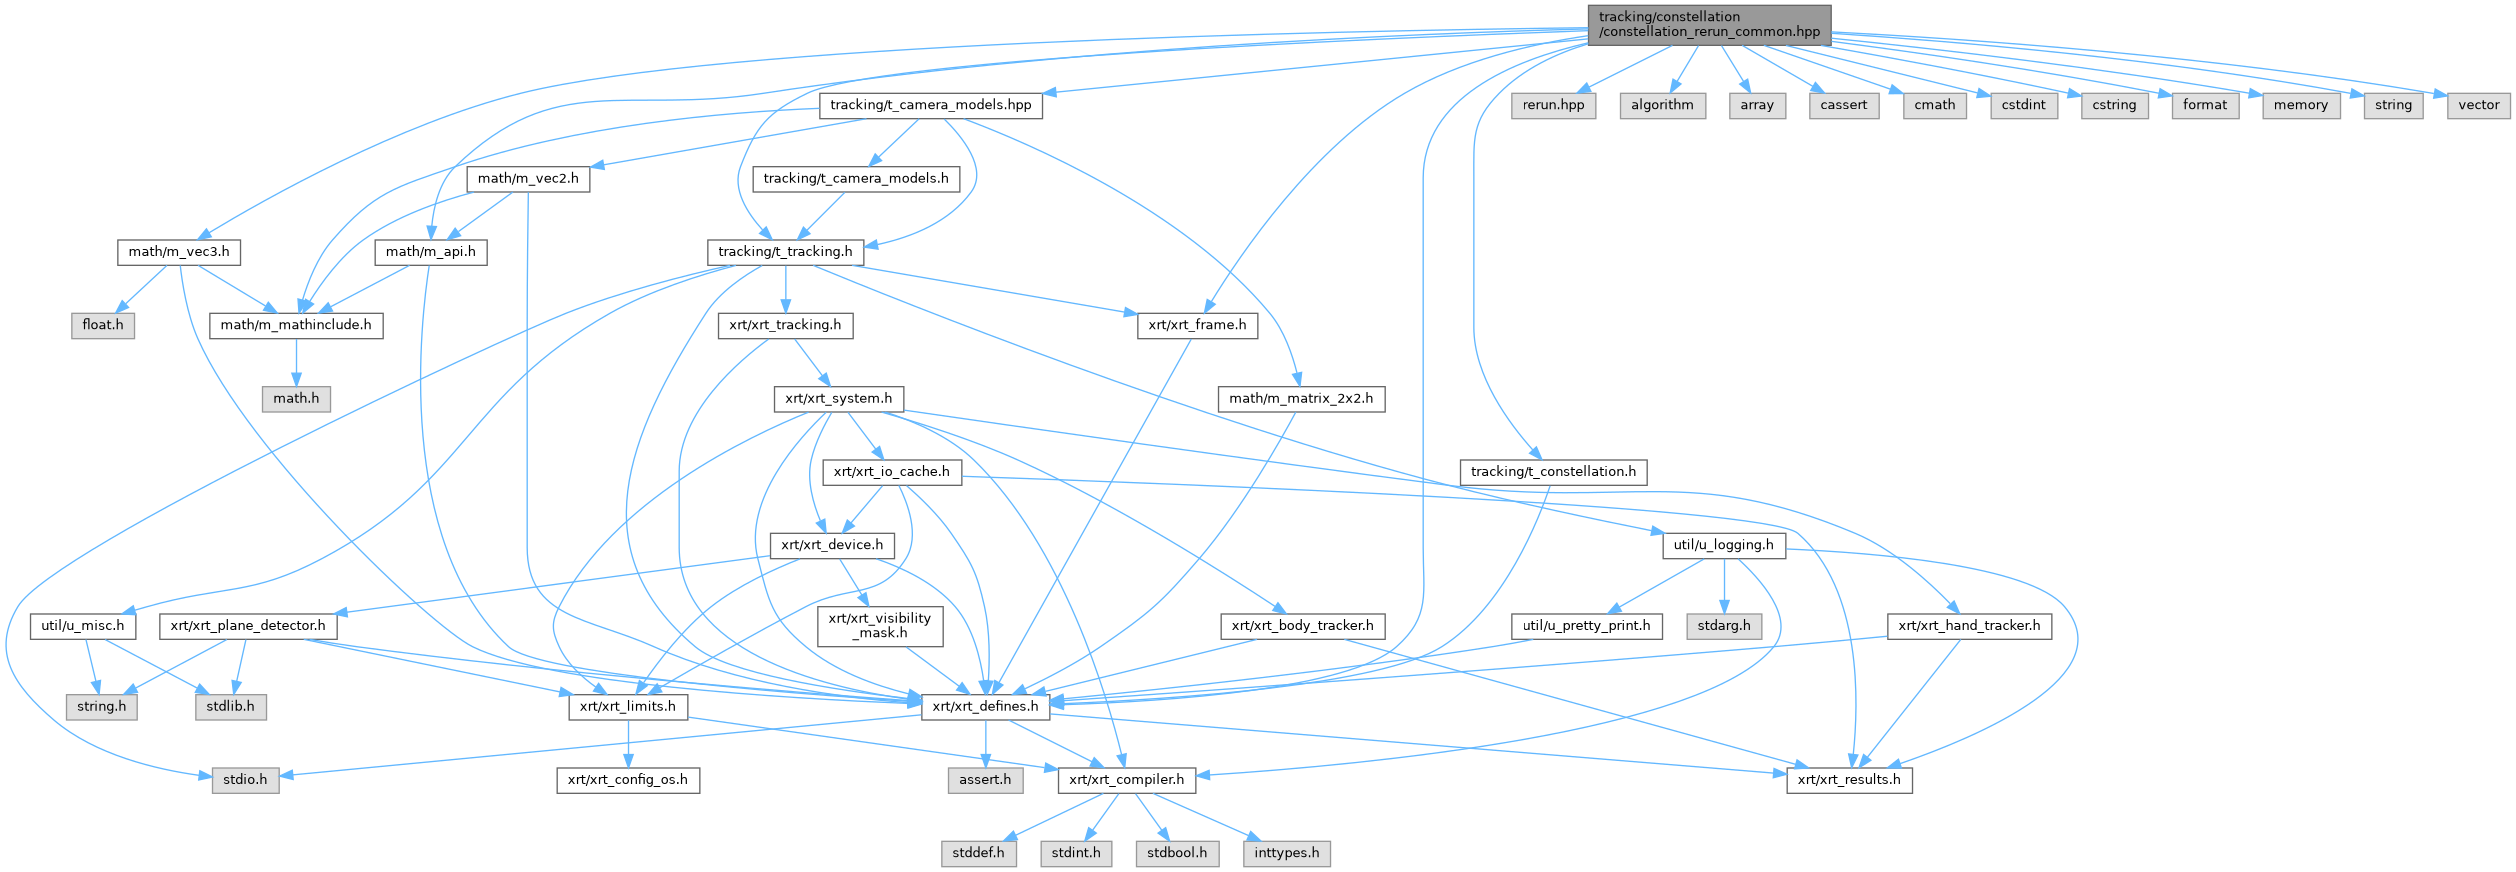
Go to the source code of this file.
Data Structures | |
| struct | xrt::tracking::constellation::RerunStream |
| The recording stream a rerun recorder logs through. More... | |
Functions | |
| xrt_pose | xrt::tracking::constellation::predictedCameraDevicePose (const xrt_pose &Tcv_world_cam, const xrt_pose &Tcv_world_device) |
| The pose the solved poses predict this camera would have observed the device at. | |
| float | xrt::tracking::constellation::orientationErrorDegrees (const xrt_quat &a, const xrt_quat &b) |
| The angle between two orientations, in degrees. | |
| float | xrt::tracking::constellation::reprojectionErrorPixels (const t_camera_model_params &dist, const xrt_pose &Tcv_world_cam, const xrt_pose &Tcv_world_device, uint32_t num_points, std::span< const xrt_vec2 > points2d, std::span< const xrt_vec3 > points3d) |
| rerun::components::Translation3D | xrt::tracking::constellation::toRerunTranslation (const xrt_vec3 &position) |
| rerun::Rotation3D | xrt::tracking::constellation::toRerunRotation (const xrt_quat &orientation) |
| rerun::Transform3D | xrt::tracking::constellation::toRerunTransform (const xrt_pose &pose, bool from_parent=true) |
| rerun::Pinhole | xrt::tracking::constellation::makePinhole (const t_camera_calibration &calibration) |
| The camera's intrinsics as the projection rerun needs to place an image in the 3D scene. | |
| rerun::Image | xrt::tracking::constellation::makeImage (const xrt_frame &frame) |
| rerun::components::Color | xrt::tracking::constellation::deviceColor (t_constellation_device_id_t device_id, float brightness) |
| A stable colour per device, so one device keeps its colour across every recorder and every view. | |
| rerun::components::Color | xrt::tracking::constellation::cameraColor (size_t mosaic_idx, size_t camera_idx, float brightness) |
| A stable colour per camera, chosen the same way as deviceColor and for the same reason. | |
| std::string_view | xrt::tracking::constellation::getWorldEntityName () |
| The root every 3D entity hangs off, so the recorders agree on where the world is. | |
| std::string | xrt::tracking::constellation::getWorldCameraEntityName (size_t mosaic_idx, size_t camera_idx) |
| Where a camera sits in the world. Its image, observations and metrics are logged under this. | |
Variables | |
| constexpr float | xrt::tracking::constellation::kLedPointRadiusM = 0.003f |
| How large a LED is drawn in the 3D views, in meters. | |
| constexpr float | xrt::tracking::constellation::kAxisLength = 0.03f |
| constexpr float | xrt::tracking::constellation::kBlobRadiusPixels = 3.0f |
| constexpr float | xrt::tracking::constellation::kTrajectoryPointRadiusM = 0.005f |
| constexpr float | xrt::tracking::constellation::kTrajectoryLineRadiusM = 0.002f |
Detailed Description
Shared internal helpers for every constellation rerun recorder.
Function Documentation
◆ cameraColor()
|
inline |
A stable colour per camera, chosen the same way as deviceColor and for the same reason.
References xrt::tracking::constellation::cameraColor().
Referenced by xrt::tracking::constellation::cameraColor().
◆ deviceColor()
|
inline |
A stable colour per device, so one device keeps its colour across every recorder and every view.
References xrt::tracking::constellation::deviceColor().
Referenced by xrt::tracking::constellation::deviceColor().
◆ getWorldCameraEntityName()
|
inline |
Where a camera sits in the world. Its image, observations and metrics are logged under this.
References xrt::tracking::constellation::getWorldCameraEntityName(), and xrt::tracking::constellation::getWorldEntityName().
Referenced by xrt::tracking::constellation::getWorldCameraEntityName(), and xrt::tracking::constellation::RerunContext::logSample().
◆ getWorldEntityName()
|
inline |
The root every 3D entity hangs off, so the recorders agree on where the world is.
References xrt::tracking::constellation::getWorldEntityName().
Referenced by xrt::tracking::constellation::getWorldCameraEntityName(), and xrt::tracking::constellation::getWorldEntityName().
◆ makePinhole()
|
inline |
The camera's intrinsics as the projection rerun needs to place an image in the 3D scene.
References t_camera_calibration::image_size_pixels, t_camera_calibration::intrinsics, and xrt::tracking::constellation::makePinhole().
Referenced by xrt::tracking::constellation::makePinhole().
◆ orientationErrorDegrees()
|
inline |
The angle between two orientations, in degrees.
References xrt::tracking::constellation::orientationErrorDegrees().
Referenced by xrt::tracking::constellation::orientationErrorDegrees().
◆ predictedCameraDevicePose()
|
inline |
The pose the solved poses predict this camera would have observed the device at.
References xrt::tracking::constellation::predictedCameraDevicePose().
Referenced by xrt::tracking::constellation::predictedCameraDevicePose().
Variable Documentation
◆ kLedPointRadiusM
|
constexpr |
How large a LED is drawn in the 3D views, in meters.
