Generic math helpers for IMU preintegration. More...
#include "os/os_time.h"#include "math/m_eigen_interop.hpp"#include "math/m_quatexpmap.hpp"#include "math/m_quatexpmap_bigceres.hpp"#include <Eigen/Core>#include <Eigen/Geometry>#include "ceres/jet.h"#include "internal_math.hpp"#include <cstring>#include <cmath>#include <mutex>#include <string>#include <algorithm>#include <span>#include <cassert>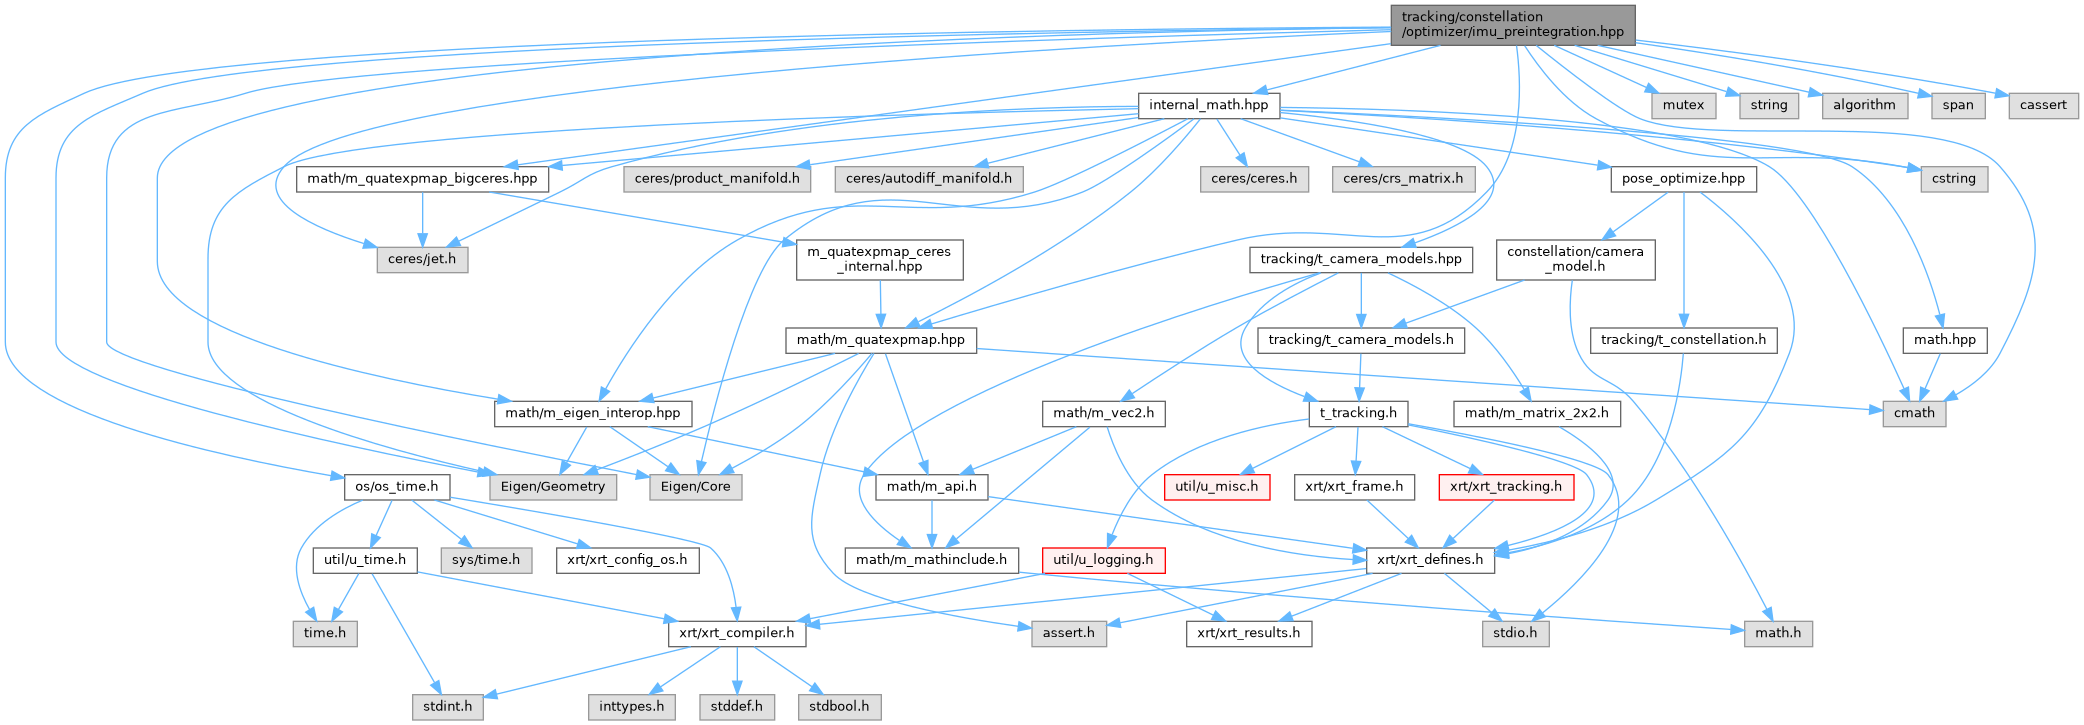
Go to the source code of this file.
Data Structures | |
| struct | xrt::tracking::constellation::optimizer::ImuBias< T > |
| A full-state IMU bias, with Accelerometer Bias, Gyroscope Bias, and Accelerometer Scale. More... | |
| struct | xrt::tracking::constellation::optimizer::PreintegratedImuSamples |
| struct | xrt::tracking::constellation::optimizer::ImuCostFunctor |
| IMU preintegration factor, between each camera keyframe. More... | |
| struct | xrt::tracking::constellation::optimizer::ImuBiasRandomWalkCostFunctor |
| IMU Bias random walk cost functor, between each keyframe. More... | |
| struct | xrt::tracking::constellation::optimizer::ImuBiasAnchorCostFunctor |
| IMU Bias anchor cost functor, to hold it at some value when marginalization has no guess for it. More... | |
Typedefs | |
| typedef ceres::Jet< double, static_cast< int >(ImuBiasStateIndex::NumIndices)> | xrt::tracking::constellation::optimizer::ImuBiasJet |
| typedef Matrix< double, kNumImuBiasCovIndices, kNumImuBiasCovIndices > | xrt::tracking::constellation::optimizer::PreintegrationCovarianceMatrix |
| [rotation; velocity; position], the order computeImuResidual writes its residual in. | |
| typedef ceres::AutoDiffCostFunction< ImuCostFunctor, PreintegratedImuSamples::kNumResiduals, WorldGravity< double >::kNumParameters, ImuBias< double >::kNumParameters, PoseWithVelocity< double >::kNumParameters, PoseWithVelocity< double >::kNumParameters > | xrt::tracking::constellation::optimizer::ImuCostFunction |
| typedef ceres::AutoDiffCostFunction< ImuBiasRandomWalkCostFunctor, ImuBiasRandomWalkCostFunctor::kNumResiduals, ImuBias< double >::kNumParameters, ImuBias< double >::kNumParameters > | xrt::tracking::constellation::optimizer::ImuBiasRandomWalkCostFunction |
| typedef ceres::AutoDiffCostFunction< ImuBiasAnchorCostFunctor, ImuBiasAnchorCostFunctor::kNumResiduals, ImuBias< double >::kNumParameters > | xrt::tracking::constellation::optimizer::ImuBiasAnchorCostFunction |
Functions | |
| PreintegratedImuSamples | xrt::tracking::constellation::optimizer::preintegrate (const std::span< const xrt_imu_sample > &imu_samples, const xrt_imu_sample &first_sample_after_end_time, const ImuBias< ImuBiasJet > &imu_bias, timepoint_ns start_time_ns, timepoint_ns end_time_ns) |
| Does IMU pre-integration on a set of IMU samples, interpolates the starting sample to the start time, and returns the pre-integrated samples. | |
| template<typename T > | |
| static void | xrt::tracking::constellation::optimizer::computeImuResidual (const PreintegratedImuSamples &imu_preintegration, const PoseWithVelocity< T > &start_T_world_device, const PoseWithVelocity< T > &end_T_world_device, const ImuBias< T > &imu_bias, const WorldGravity< T > &world_gravity, Vector< T, PreintegratedImuSamples::kNumResiduals > &residual) |
Variables | |
| constexpr double | xrt::tracking::constellation::optimizer::kGyroNoiseDensity = 2.44e-4 |
| BMI055 gyroscope noise density, 0.014 deg/s/sqrt(Hz) from the datasheet, in rad/s/sqrt(Hz). | |
| constexpr double | xrt::tracking::constellation::optimizer::kAccelNoiseDensity = 1.47e-3 |
| BMI055 accelerometer noise density, 150 ug/sqrt(Hz) from the datasheet, in (m/s^2)/sqrt(Hz). | |
| constexpr double | xrt::tracking::constellation::optimizer::kAccelBiasRandomWalkSigma = 1e-3 |
| constexpr double | xrt::tracking::constellation::optimizer::kGyroBiasRandomWalkSigma = 1e-4 |
| constexpr double | xrt::tracking::constellation::optimizer::kAccelScaleRandomWalkSigma = 1e-5 |
| constexpr double | xrt::tracking::constellation::optimizer::kAccelBiasAnchorSigma = 0.687 |
| constexpr double | xrt::tracking::constellation::optimizer::kGyroBiasAnchorSigma = 0.0175 |
| constexpr double | xrt::tracking::constellation::optimizer::kAccelScaleAnchorSigma = 0.05 |
| constexpr double | xrt::tracking::constellation::optimizer::kMaxAccelBias = 1.0 |
| Largest accelerometer bias to allow, in m/s^2. The BMI055's zero-g offset is +-70mg, so this is ~1.4x that. | |
| constexpr double | xrt::tracking::constellation::optimizer::kMaxGyroBias = 0.05 |
| Largest gyroscope bias to allow, in rad/s. The BMI055's zero-rate offset is +-1 deg/s, this is ~3 deg/s. | |
| constexpr double | xrt::tracking::constellation::optimizer::kMinAccelScale = 0.8 |
| constexpr double | xrt::tracking::constellation::optimizer::kMaxAccelScale = 1.0 / kMinAccelScale |
| constexpr time_duration_ns | xrt::tracking::constellation::optimizer::kKeyframeGroupingToleranceNs = U_TIME_1MS_IN_NS |
| Camera samples from the same mosaic closer together than this are treated as one keyframe. | |
| static constexpr int | xrt::tracking::constellation::optimizer::kImuBiasRotCovIndex = static_cast<int>(ImuBiasCovarianceIndex::RotX) |
| static constexpr int | xrt::tracking::constellation::optimizer::kImuBiasVelCovIndex = static_cast<int>(ImuBiasCovarianceIndex::VelocityX) |
| static constexpr int | xrt::tracking::constellation::optimizer::kImuBiasPosCovIndex = static_cast<int>(ImuBiasCovarianceIndex::PositionX) |
| static constexpr int | xrt::tracking::constellation::optimizer::kNumImuBiasCovIndices = static_cast<int>(ImuBiasCovarianceIndex::NumIndices) |
Detailed Description
Generic math helpers for IMU preintegration.
Typedef Documentation
◆ PreintegrationCovarianceMatrix
| typedef Matrix<double, kNumImuBiasCovIndices, kNumImuBiasCovIndices> xrt::tracking::constellation::optimizer::PreintegrationCovarianceMatrix |
[rotation; velocity; position], the order computeImuResidual writes its residual in.
Function Documentation
◆ preintegrate()
| PreintegratedImuSamples xrt::tracking::constellation::optimizer::preintegrate | ( | const std::span< const xrt_imu_sample > & | imu_samples, |
| const xrt_imu_sample & | first_sample_after_end_time, | ||
| const ImuBias< ImuBiasJet > & | imu_bias, | ||
| timepoint_ns | start_time_ns, | ||
| timepoint_ns | end_time_ns | ||
| ) |
Does IMU pre-integration on a set of IMU samples, interpolates the starting sample to the start time, and returns the pre-integrated samples.
- Parameters
-
imu_samples The IMU samples to preintegrate first_sample_after_end_time The first sample after the end timestamp imu_bias The Jet-seeded IMU biases start_time_ns The start time of the preintegration end_time_ns The end time of the preintegration
References xrt::tracking::constellation::optimizer::preintegrate(), xrt::tracking::constellation::optimizer::PreintegratedImuSamples::Q_start_end, and xrt::tracking::constellation::optimizer::PreintegratedImuSamples::whitening.
Referenced by xrt::tracking::constellation::optimizer::preintegrate().
Variable Documentation
◆ kAccelNoiseDensity
|
constexpr |
BMI055 accelerometer noise density, 150 ug/sqrt(Hz) from the datasheet, in (m/s^2)/sqrt(Hz).
Referenced by xrt::tracking::constellation::optimizer::propagateCovariance().
◆ kGyroNoiseDensity
|
constexpr |
BMI055 gyroscope noise density, 0.014 deg/s/sqrt(Hz) from the datasheet, in rad/s/sqrt(Hz).
Referenced by xrt::tracking::constellation::optimizer::propagateCovariance().
◆ kKeyframeGroupingToleranceNs
|
constexpr |
Camera samples from the same mosaic closer together than this are treated as one keyframe.
Sometimes frame timestamps are a couple microseconds off due to guesswork/interpolation, this groups them together.
- Todo:
- We should by default group based on sequence_id! However, to make external users more reliable, let's not rely on that just yet until the infrasturcture for matching sequence ID across multiple cameras is available.
Referenced by xrt::tracking::constellation::optimizer::sensor_fusion::SensorFusion::processCameraSampleLocked().
◆ kMaxAccelBias
|
constexpr |
Largest accelerometer bias to allow, in m/s^2. The BMI055's zero-g offset is +-70mg, so this is ~1.4x that.
◆ kMaxGyroBias
|
constexpr |
Largest gyroscope bias to allow, in rad/s. The BMI055's zero-rate offset is +-1 deg/s, this is ~3 deg/s.
