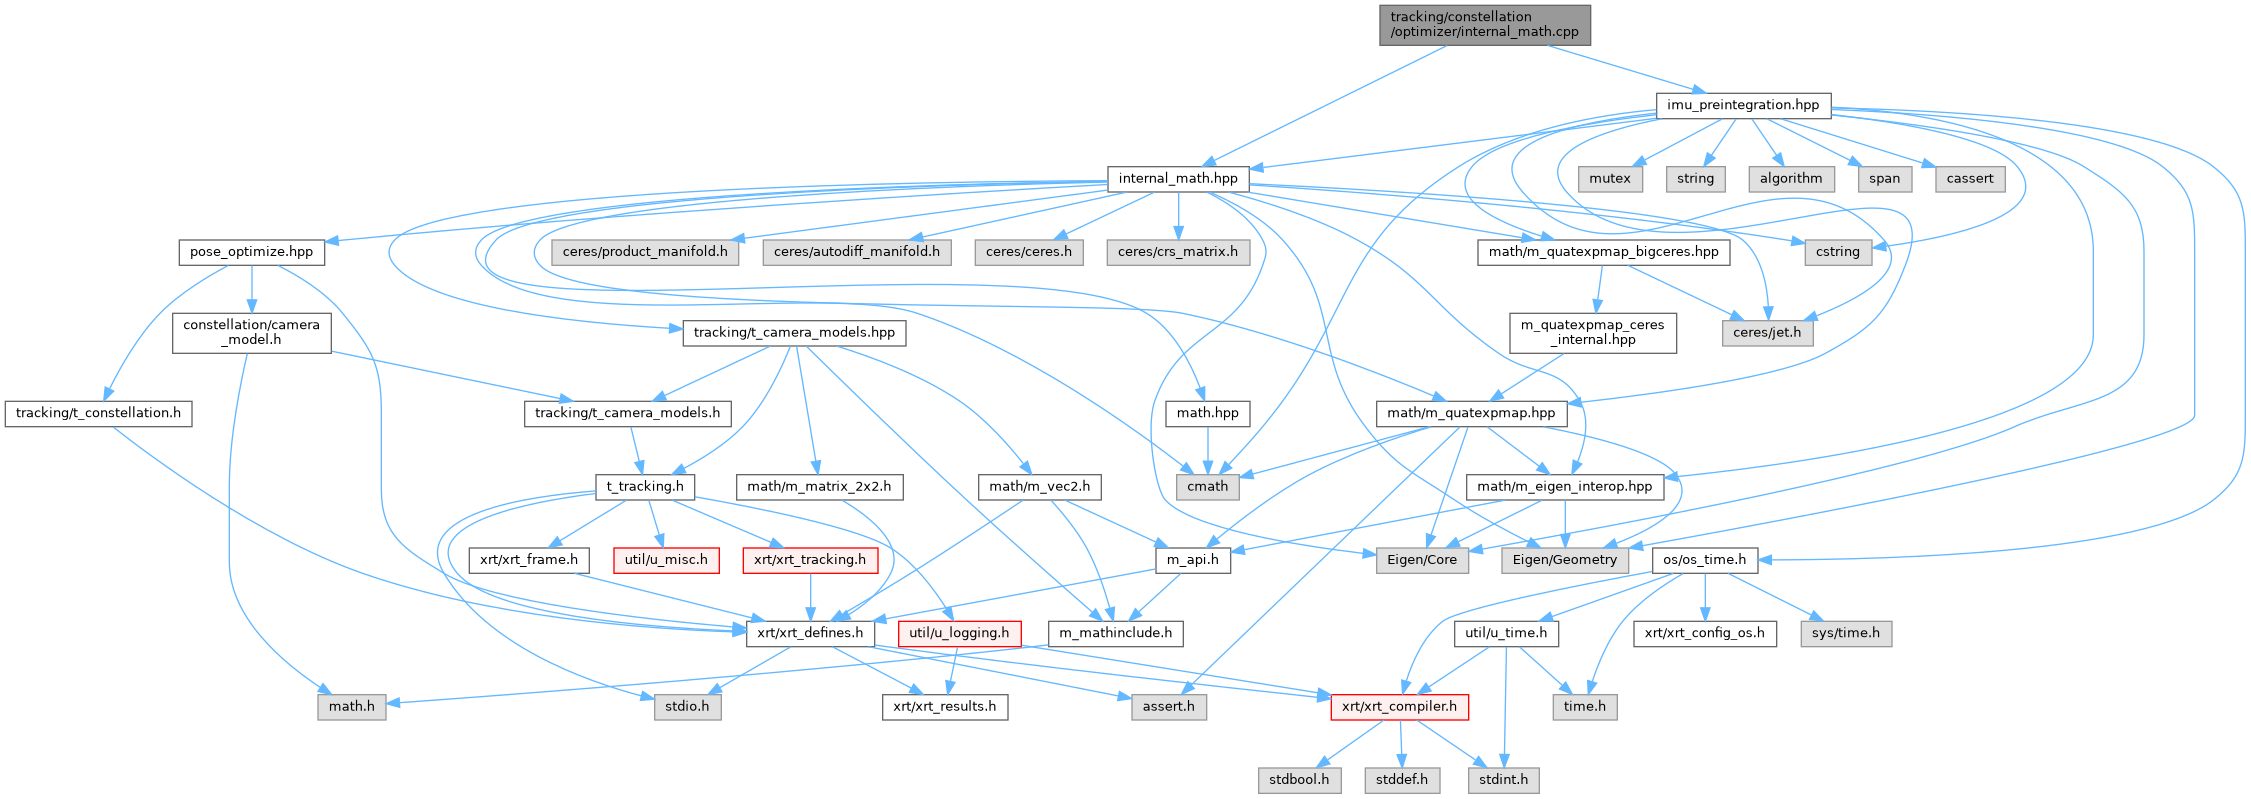
Generic math helpers for constellation optimizer code. More...
Functions | |
| static Matrix3d | xrt::tracking::constellation::optimizer::skew (const Vector3d &v) |
| The matrix which cross-products with v, so skew(v) * u == v.cross(u). | |
| static Matrix3d | xrt::tracking::constellation::optimizer::rightJacobianSo3 (const Vector3d &phi) |
The right Jacobian of SO(3), which converts a perturbation of a rotation vector into the body-frame rotation it produces: Exp(phi + delta) ~= Exp(phi) * Exp(rightJacobianSo3(phi) * delta). | |
| template<typename Derived > | |
| static Matrix< double, Derived::RowsAtCompileTime *Derived::ColsAtCompileTime, ImuBias< double >::kNumParameters > | xrt::tracking::constellation::optimizer::extractJacobianFromJetMatrix (const MatrixBase< Derived > &m) |
| template<int N> | |
| static Matrix3d | xrt::tracking::constellation::optimizer::quaternionJetToSO3Jacobian (const Quaternion< ceres::Jet< double, N > > &q_jet, int parameter_offset) |
| static void | xrt::tracking::constellation::optimizer::propagateCovariance (const Quaterniond &Q_start_cur, const Vector3d &corrected_accel, const Vector3d &corrected_gyro, const Vector3d &accel_scale, double dt, PreintegrationCovarianceMatrix &covariance) |
| Propagates the covariance for this sample. | |
| static void | xrt::tracking::constellation::optimizer::integrateSingleSample (const xrt_imu_sample &sample, double dt, const Vector3< ImuBiasJet > &accel_bias, const Vector3< ImuBiasJet > &gyro_bias, const Vector3< ImuBiasJet > &accel_scale, Quaternion< ImuBiasJet > &Q_start_cur, Vector3< ImuBiasJet > &delta_velocity, Vector3< ImuBiasJet > &delta_position, PreintegrationCovarianceMatrix &covariance) |
| static void | xrt::tracking::constellation::optimizer::robustComputeSqrtAndPinvSqrt (const MatrixXd &a, MatrixXd &out_j, MatrixXd &out_j_pinv_t) |
Decompose a symmetric positive semi-definite a into a square root and the transposed pseudo-inverse of that square root, dropping the eigenvalues that are numerically indistinguishable from zero so that a rank-deficient input still gives usable factors instead of infinities. | |
| FactorFitness | xrt::tracking::constellation::optimizer::evaluateFactorFitness (ceres::Problem &problem, const std::vector< ceres::ResidualBlockId > &residual_blocks) |
| Measures how well one kind of factor was fit, at whatever the problem's parameters currently hold. | |
| void | xrt::tracking::constellation::optimizer::matrixCrsToEigen (const ceres::CRSMatrix &mat_crs, Eigen::MatrixXd &mat) |
| Converts a CRS matrix to a dense Eigen matrix. | |
| void | xrt::tracking::constellation::optimizer::marginalize (const VectorXd &residual, const MatrixXd &jacobian, const int num_base_states, VectorXd &out_e0, MatrixXd &out_j) |
Marginalize the first num_base_states states out of the linearized system given by jacobian and residual, handing back the linear prior that replaces them. | |
| PreintegratedImuSamples | xrt::tracking::constellation::optimizer::preintegrate (const std::span< const xrt_imu_sample > &imu_samples, const xrt_imu_sample &first_sample_after_end_time, const ImuBias< ImuBiasJet > &imu_bias, timepoint_ns start_time_ns, timepoint_ns end_time_ns) |
| Does IMU pre-integration on a set of IMU samples, interpolates the starting sample to the start time, and returns the pre-integrated samples. | |
Detailed Description
Generic math helpers for constellation optimizer code.
Function Documentation
◆ evaluateFactorFitness()
| FactorFitness xrt::tracking::constellation::optimizer::evaluateFactorFitness | ( | ceres::Problem & | problem, |
| const std::vector< ceres::ResidualBlockId > & | residual_blocks | ||
| ) |
Measures how well one kind of factor was fit, at whatever the problem's parameters currently hold.
Both factor types are whitened, so this is directly comparable between them and against 1.
- Parameters
-
problem The problem, evaluated at its current parameter values. residual_blocks The blocks belonging to this kind of factor.
References xrt::tracking::constellation::optimizer::evaluateFactorFitness(), and xrt::tracking::constellation::optimizer::FactorFitness::num_residuals.
Referenced by xrt::tracking::constellation::optimizer::evaluateFactorFitness().
◆ marginalize()
| void xrt::tracking::constellation::optimizer::marginalize | ( | const VectorXd & | residual, |
| const MatrixXd & | jacobian, | ||
| const int | num_base_states, | ||
| VectorXd & | out_e0, | ||
| MatrixXd & | out_j | ||
| ) |
Marginalize the first num_base_states states out of the linearized system given by jacobian and residual, handing back the linear prior that replaces them.
Inspired/specialized from MarginalizationError::marginalizeOut() from OKVIS.
References xrt::tracking::constellation::optimizer::marginalize(), and xrt::tracking::constellation::optimizer::robustComputeSqrtAndPinvSqrt().
Referenced by xrt::tracking::constellation::optimizer::marginalize().
◆ matrixCrsToEigen()
| void xrt::tracking::constellation::optimizer::matrixCrsToEigen | ( | const ceres::CRSMatrix & | mat_crs, |
| Eigen::MatrixXd & | mat | ||
| ) |
Converts a CRS matrix to a dense Eigen matrix.
References xrt::tracking::constellation::optimizer::matrixCrsToEigen().
Referenced by xrt::tracking::constellation::optimizer::matrixCrsToEigen().
◆ preintegrate()
| PreintegratedImuSamples xrt::tracking::constellation::optimizer::preintegrate | ( | const std::span< const xrt_imu_sample > & | imu_samples, |
| const xrt_imu_sample & | first_sample_after_end_time, | ||
| const ImuBias< ImuBiasJet > & | imu_bias, | ||
| timepoint_ns | start_time_ns, | ||
| timepoint_ns | end_time_ns | ||
| ) |
Does IMU pre-integration on a set of IMU samples, interpolates the starting sample to the start time, and returns the pre-integrated samples.
- Parameters
-
imu_samples The IMU samples to preintegrate first_sample_after_end_time The first sample after the end timestamp imu_bias The Jet-seeded IMU biases start_time_ns The start time of the preintegration end_time_ns The end time of the preintegration
References xrt::tracking::constellation::optimizer::preintegrate(), xrt::tracking::constellation::optimizer::PreintegratedImuSamples::Q_start_end, and xrt::tracking::constellation::optimizer::PreintegratedImuSamples::whitening.
Referenced by xrt::tracking::constellation::optimizer::preintegrate().
◆ propagateCovariance()
|
static |
Propagates the covariance for this sample.
- Parameters
-
[in] Q_start_cur Rotation accumulated before this sample. [in] corrected_accel Bias and scale-corrected acceleration, in the IMU frame. [in] corrected_gyro Bias-corrected gyroscope reading. [in] accel_scale The accelerometer scale. dt Delta time [out] covariance Out covariance matrix
References xrt::tracking::constellation::optimizer::kAccelNoiseDensity, xrt::tracking::constellation::optimizer::kGyroNoiseDensity, xrt::tracking::constellation::optimizer::propagateCovariance(), xrt::auxiliary::math::quat_exp_so3(), xrt::tracking::constellation::optimizer::rightJacobianSo3(), and xrt::tracking::constellation::optimizer::skew().
Referenced by xrt::tracking::constellation::optimizer::propagateCovariance().
◆ rightJacobianSo3()
|
static |
The right Jacobian of SO(3), which converts a perturbation of a rotation vector into the body-frame rotation it produces: Exp(phi + delta) ~= Exp(phi) * Exp(rightJacobianSo3(phi) * delta).
- Parameters
-
phi The rotation vector to evaluate at, in radians.
References xrt::tracking::constellation::optimizer::rightJacobianSo3(), and xrt::tracking::constellation::optimizer::skew().
Referenced by xrt::tracking::constellation::optimizer::propagateCovariance(), and xrt::tracking::constellation::optimizer::rightJacobianSo3().
◆ robustComputeSqrtAndPinvSqrt()
|
static |
Decompose a symmetric positive semi-definite a into a square root and the transposed pseudo-inverse of that square root, dropping the eigenvalues that are numerically indistinguishable from zero so that a rank-deficient input still gives usable factors instead of infinities.
With the eigendecomposition a = E S E^T, this hands back out_j = S^1/2 E^T and out_j_pinv_t = S^-1/2 E^T, so that out_j^T * out_j == a and out_j_pinv_t == (out_j^-1)^T.
This is what OKVIS does at the end of MarginalizationError::updateErrorComputation(), minus its Jacobi preconditioner: out_j is its J_ and out_j_pinv_t its J_pinv_T.
References xrt::tracking::constellation::optimizer::robustComputeSqrtAndPinvSqrt().
Referenced by xrt::tracking::constellation::optimizer::marginalize(), and xrt::tracking::constellation::optimizer::robustComputeSqrtAndPinvSqrt().
◆ skew()
|
static |
The matrix which cross-products with v, so skew(v) * u == v.cross(u).
References xrt::tracking::constellation::optimizer::skew().
Referenced by xrt::tracking::constellation::optimizer::propagateCovariance(), xrt::tracking::constellation::optimizer::rightJacobianSo3(), and xrt::tracking::constellation::optimizer::skew().
