Metrics for constellation tracking poses. More...
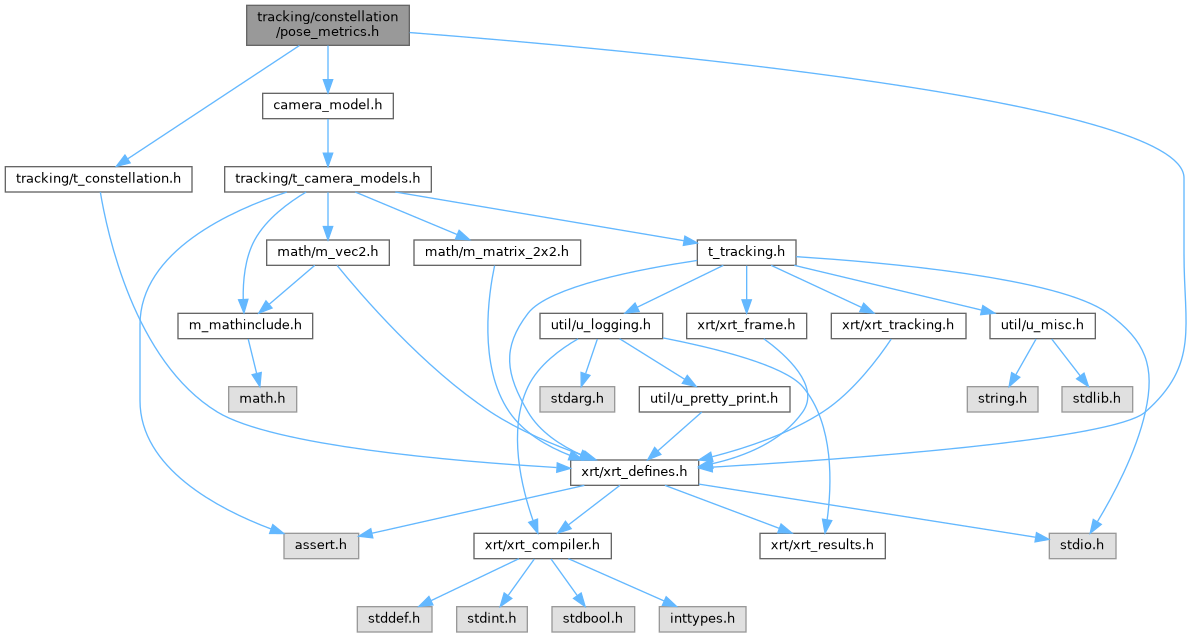
Go to the source code of this file.
Data Structures | |
| struct | pose_rect |
| struct | pose_metrics |
| struct | pose_metrics_visible_led_info |
| struct | pose_metrics_blob_match_info |
Macros | |
| #define | MAX_OBJECT_LEDS 64 |
| #define | WORST_REPROJECTION_ERROR 10.0 |
| #define | CLOSEST_ACCEPTABLE_POSE_M 0.05 |
| Device origin poses closer than this are probably invalid solves. | |
| #define | FARTHEST_ACCEPTABLE_POSE_M 15.0 |
| Poses farther away than this are definitely invalid solves. | |
| #define | POSE_SET_FLAGS(score, f) ((score)->match_flags |= (f)) |
| #define | POSE_CLEAR_FLAGS(score, f) ((score)->match_flags &= ~(f)) |
| #define | POSE_HAS_FLAGS(score, f) (((score)->match_flags & (f)) == (f)) |
| #define | POSE_CLEAR_VALID(score) POSE_CLEAR_FLAGS(score, POSE_MATCH_GOOD | POSE_MATCH_STRONG) |
Enumerations | |
| enum | pose_match_flags { POSE_MATCH_GOOD = 1 << 0 , POSE_MATCH_STRONG = 1 << 1 , POSE_MATCH_POSITION = 1 << 2 , POSE_MATCH_ORIENT = 1 << 3 , POSE_HAD_PRIOR = 1 << 4 , POSE_MATCH_LED_IDS = 1 << 5 , POSE_MATCH_DEGENERATE = 1 << 6 } |
Functions | |
| static XRT_MAYBE_UNUSED bool | pose_rect_has_area (struct pose_rect *rect) |
| void | pose_metrics_match_pose_to_blobs (const struct xrt_pose *pose, struct t_blob *blobs, int num_blobs, struct t_constellation_tracker_led_model *led_model, t_constellation_device_id_t device_id, struct camera_model *calib, struct pose_metrics_blob_match_info *match_info) |
| void | pose_metrics_evaluate_pose (struct pose_metrics *score, const struct xrt_pose *pose, struct t_blob *blobs, int num_blobs, struct t_constellation_tracker_led_model *leds_model, t_constellation_device_id_t device_id, struct camera_model *calib, struct pose_rect *out_bounds) |
| void | pose_metrics_evaluate_pose_with_prior (struct pose_metrics *score, const struct xrt_pose *pose, bool prior_must_match, const struct xrt_pose *pose_prior, const struct xrt_vec3 *pos_error_thresh, const struct xrt_vec3 *rot_error_thresh, struct t_blob *blobs, int num_blobs, struct t_constellation_tracker_led_model *led_model, t_constellation_device_id_t device_id, struct camera_model *calib, struct pose_rect *out_bounds) |
| bool | pose_metrics_score_is_better_pose (struct pose_metrics *old_score, struct pose_metrics *new_score) |
| Compares whether new_score is a better pose than old_score. | |
Detailed Description
Metrics for constellation tracking poses.
Macro Definition Documentation
◆ CLOSEST_ACCEPTABLE_POSE_M
| #define CLOSEST_ACCEPTABLE_POSE_M 0.05 |
Device origin poses closer than this are probably invalid solves.
◆ FARTHEST_ACCEPTABLE_POSE_M
| #define FARTHEST_ACCEPTABLE_POSE_M 15.0 |
Poses farther away than this are definitely invalid solves.
Enumeration Type Documentation
◆ pose_match_flags
| enum pose_match_flags |
| Enumerator | |
|---|---|
| POSE_MATCH_GOOD | A reasonable pose match - most LEDs matched to within a few pixels error. |
| POSE_MATCH_STRONG | A strong pose match is a match with very low error. |
| POSE_MATCH_POSITION | The position of the pose matched the prior well. |
| POSE_MATCH_ORIENT | The orientation of the pose matched the prior well. |
| POSE_HAD_PRIOR | If a pose prior was supplied when calculating the score, then rot/trans_error are set. |
| POSE_MATCH_LED_IDS | The LED IDs on the blobs all matched the LEDs we thought (or were unassigned) |
| POSE_MATCH_DEGENERATE | Set when the pose cannot explain the device entirely on it's own. One case is when too few blobs matched for the reprojection error to say anything about the fit, a P3P solve or fewer. Such a solve reproduces its own points by construction, so its error is near zero whether or not the pose is right. Another case this may be triggered is when the amount of blobs is too low for the LED model in question to be confident about a slow solve. See t_constellation_tracker_led_model_match_parameters. |
Function Documentation
◆ pose_metrics_score_is_better_pose()
| bool pose_metrics_score_is_better_pose | ( | struct pose_metrics * | old_score, |
| struct pose_metrics * | new_score | ||
| ) |
Compares whether new_score is a better pose than old_score.
- Parameters
-
old_score The old score to compare against. new_score The new score to compare against the old score.
- Returns
- true if the new score is a better pose than the old score, false otherwise.
References pose_metrics::orient_error, POSE_HAD_PRIOR, POSE_MATCH_DEGENERATE, POSE_MATCH_GOOD, and POSE_MATCH_STRONG.
